01
Pick and place
Reach into a tote or onto a table, grasp an everyday object, and put it where the task says it belongs.
PARTH
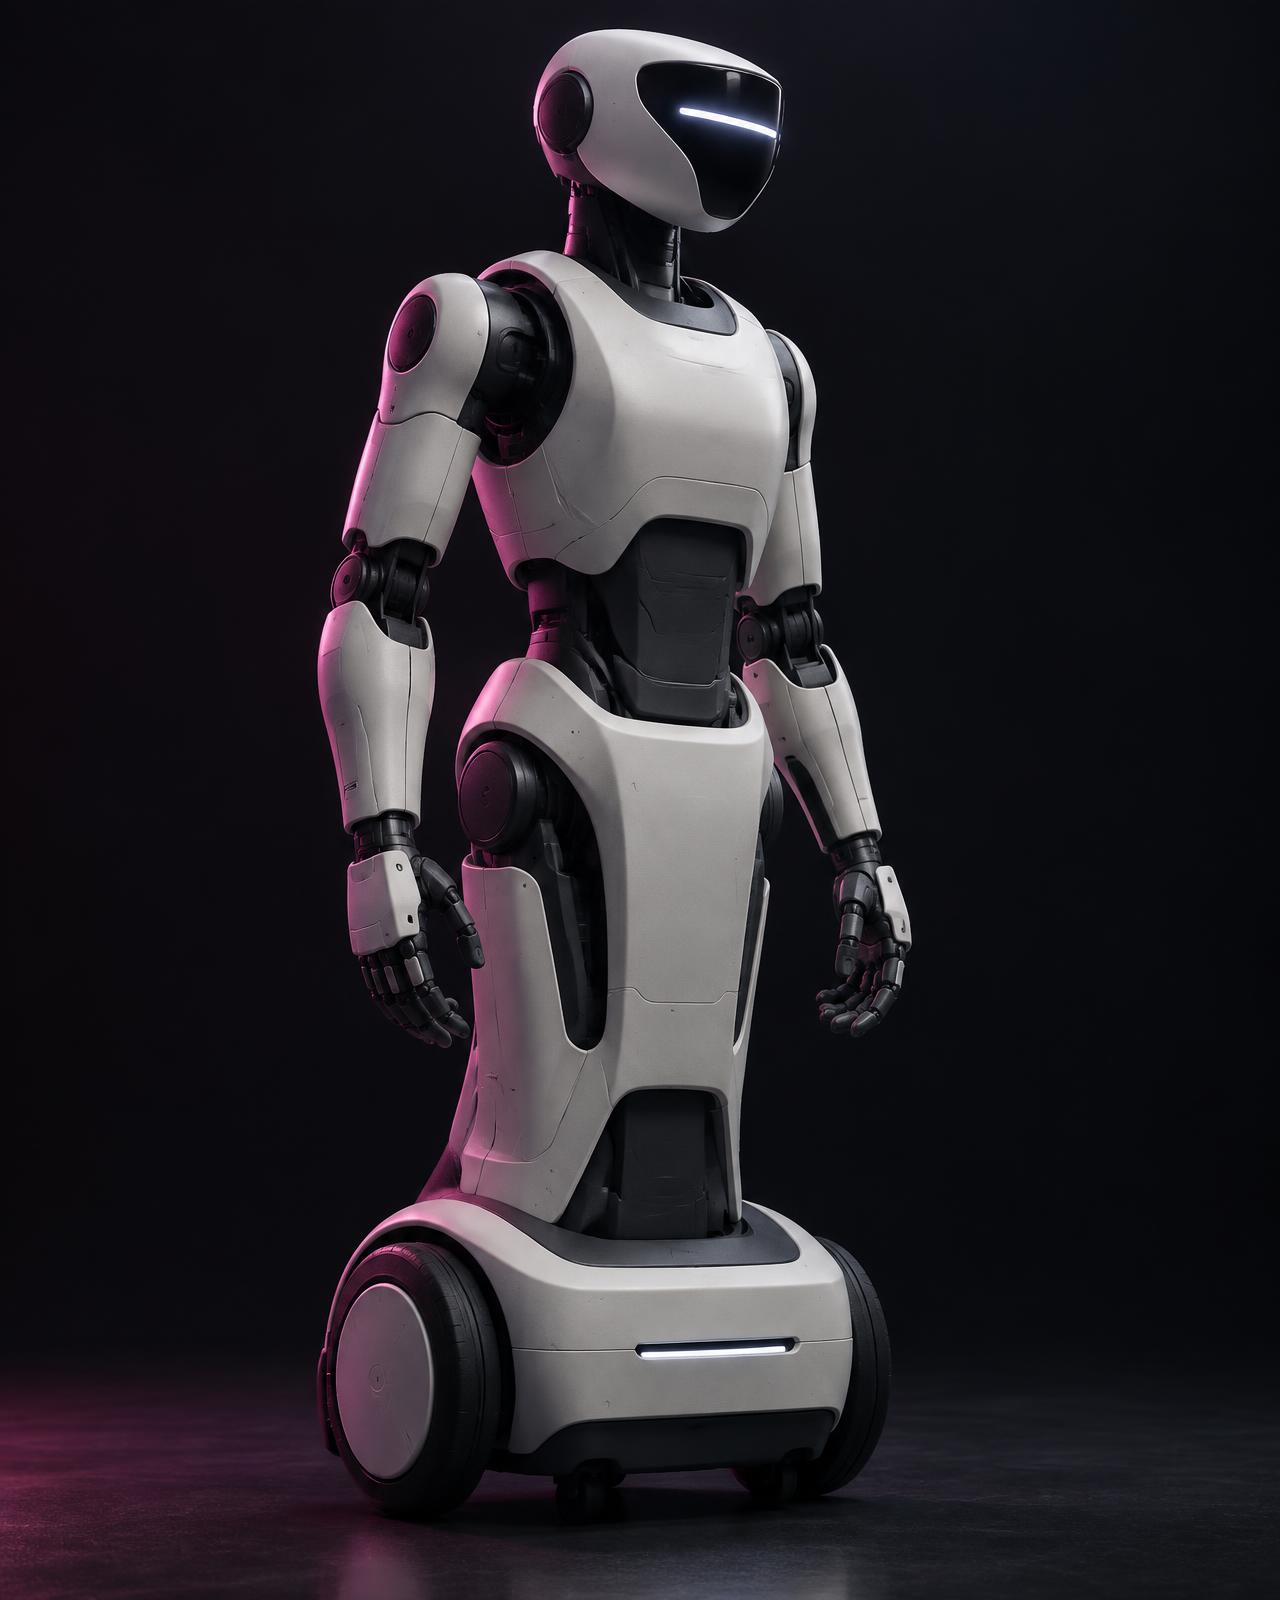
PARTH is our humanoid robot: human-scale, electrically actuated, and built for handling work in indoor spaces designed for people. CuriousDevs Robotics builds the body and its real-time control; OJAS provides the intelligence.
What it is for
01
Reach into a tote or onto a table, grasp an everyday object, and put it where the task says it belongs.
02
Move a held object across a defined indoor route and hand it to the next station.
03
Human-scale reach and height, so aisles, benches and shelving stay as they are.
Anatomy
Component
3 DOF · FORCE/TORQUE SENSOR
Force/torque sensing at the wrist is what makes contact-rich handling measurable instead of guessed.
Why this shape
Human form fits workplaces sized for human reach, walking and tools. The price is difficulty: balance, actuators, safety around people and cost are all harder than for a fixed or wheeled machine. Human shape is chosen for redeployability, not novelty.
Configurations
01
Upper body on a fixed stand. Manipulation, perception and the full software path, with no balance problem in the way.
02
The same upper body on a wheeled base. Indoor navigation and mobile manipulation.
03
Two six-degree-of-freedom legs for full humanoid mobility on level floors.
All three configurations share one head, torso, arms, hands, compute, software and actuator families. Baseline kinematics: neck 2, waist 1–3, each arm 7, each leg 6 — 29 to 31 degrees of freedom excluding hands.
Safety
MODELS
Proposes intent only
No authority over safety-critical actuation. Every layer below can refuse what it proposes.
OJAS
Authorises or refuses
Authorisation, forbidden actions, task and environment constraints, evaluated before anything is sent down.
PARTH ROBOTICS
Validates parameters
Preconditions, parameter ranges and timeouts checked before a skill is allowed to execute.
REAL-TIME CONTROL
Clamps and stops
Joint position, velocity, acceleration, current, thermal and workspace limits enforced deterministically.
INDEPENDENT
Removes power
Emergency-stop chain, watchdogs and Safe Torque Off to every drive, through a main contactor, independent of software state.
Authority increases downward
No single failure — in a model, a program or a component — should cause uncontrolled motion. Safe states are defined per configuration: move to a stable posture where possible, then remove torque. Machines under test run on a gantry or harness so power can be removed without fall damage.
Boundaries
PARTH is at architecture-definition stage. Illustrations are configurations under design, not products.
No capability in the current edition is claimed as demonstrated.
Height, mass, payload, runtime and speed remain open until design review.
The safety architecture follows recognised standards. It does not claim certification against them.
Unstructured domestic spaces and close physical contact are explicitly out of scope.
FIGURES ON THIS PAGE ARE RECOMMENDED ENGINEERING TARGETS · PUBLISHED AS RESULTS ONLY ONCE MEASURED
PARTH is the first platform to come out of CuriousDevs Robotics. The division builds the machines; CuriousDevs Intelligence builds what runs on them.