Physical AI Lab
Intelligence that moves matter.
- Intelligence
- OJAS
- Embodiment
- PARTH
- Target hardware
- Existing edge compute
- Status
- Early engineering
01 · Why this layer
A model can describe a scene. It cannot decide whether acting on it is permitted right now.
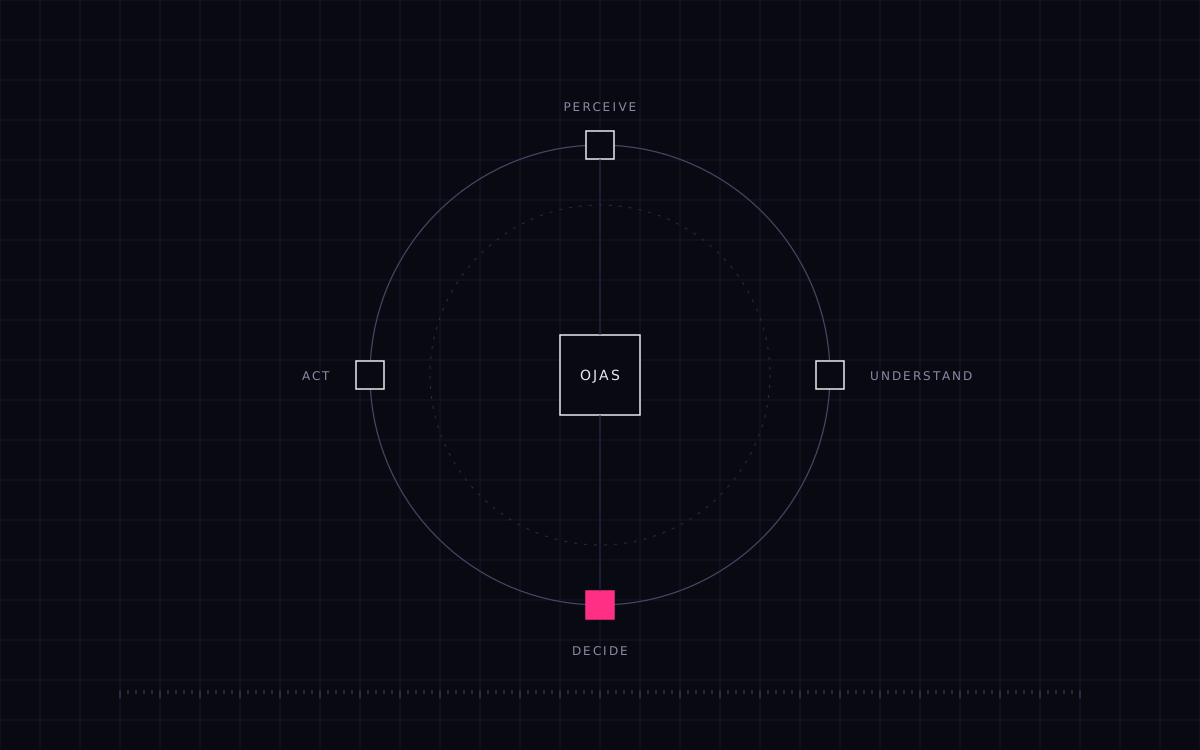
Perceive
Understand
Decide
Act
02 · Brain and body
One decides. One moves.
Intelligence · The brain
OJAS
A general-purpose execution runtime for Physical AI, in early engineering. It is designed to connect models to cameras, sensors and machines through adapters, and to put a policy check with no machine learning in it between every proposal and every actuator.
- Designed to run a CuriousDevs model, a third-party model or your own — behind one contract
- Designed so that every action passes an explicit policy check
- Planned adapters to ROS 2, simulation and other backends
- Targeting Jetson-class, Raspberry Pi and x86 GPU hardware
Embodiment · The body · Paused
PARTH
A human-scale robot designed to bring OJAS into the physical world. PARTH is a customer of OJAS, not its owner — the same runtime is meant to run machines we did not build. Work on PARTH is paused until OJAS can drive a machine end to end.
- Designed with independent safety hardware below every software layer
- Stationary, wheeled and bipedal configurations planned on one stack
- Commercial actuators, compute and sensors before anything custom
03 · The stack
Model-agnostic. Policy-gated. On hardware that already exists.
Perception, world state, reasoning, planning, memory, rules and policies, tools and actions, telemetry and a device abstraction — the execution system between the model and the machine.
Ownership
CuriousDevs Intelligence
INTENT FLOWS DOWN · STATE FLOWS UP · OJAS RUNTIME OWNS THE MODEL-TO-ACTION PATH
04 · Where it stands
What exists, and what does not yet.
| Component | Status | Next step |
|---|---|---|
| OJAS Runtime v0.1 | In engineering — architecture first | Canonical interfaces, runtime core and a first adapter |
| Backend adapters | Design | Prove portability with a second backend |
| Data and training platform | Research | Begins once the runtime is stable |
| OJAS Model | Research | Start from open VLA models, then train our own |
| PARTH | Paused | Resumes when OJAS can drive a machine end to end |
STATUS AS OF OCTOBER 2026
Founding team
Build OJAS with us.
We are forming a small founding team of two or three engineers for the runtime: robotics middleware, real-time systems and edge inference. Send the hardest thing you have shipped.
Partners and early users
Have a machine, a task and a tolerance?
Describe the station, not the vision: the machine, the task, and what happens today when it fails. Research partners, labs and grant programmes are welcome too.